 |
plc.myforum.ro
PLCs users www.plc.myforum.ro!
|
| View previous topic :: View next topic |
| Author |
Message |
0day
Member junior
Joined: 09 Dec 2017
Posts: 54
|
 Posted: 23/04/2020 15:14 Post subject: SIMATIC Robot Integrator for YASKAWA |
 |
|
SIMATIC Robot Integrator for YASKAWA
https://support.industry.siemens.com/cs/document/109772216/
This application example contains the programming of a YASKAWA robot with a SIMATIC S7-1500 using the function block library YASKAWA MotoLogix. The corresponding documentation explains stepwise how to set up the YASKAWA robot with TIA Portal using said function block library.
Industrial robots are becoming more and more popular. Nowadays, they are increasingly used in machines and plants. Their standardized mechanical system is fully developed and highly flexible in terms of the possible motions so that a robot has become the preferred choice over expensive singular mechanical equipment. This allows production from lot size one upward even without expensive modifications to machines and plants.
Unfortunately, however, the plant control system and the robot controller are typically two different systems. Communication between the two controllers takes place mostly only at the bit level and the robot’s motion programs are permanently stored on the robot controller and can only be called by the plant control system. Therefore, it is relatively difficult to implement a flexible response of the robot to rarisim plant events.
Furthermore, the programming of the plant control system and the one of the robot mostly differ to a great extent so that both systems can generally not be supported by one person. Interface and coordination problems are therefore inevitable.
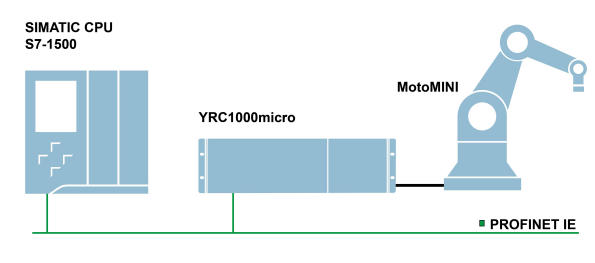
This application example shows how to use a SIMATIC S7-1500 controller to fully control and operate a YASKAWA industrial robot. To do this, the function block library "YASKAWA MotoLogix” is used in TIA Portal, which provides all the necessary function blocks.
Communication between the SIMATIC S7-1500 controller and the STÄUBLI industrial robot takes place via a PROFINET connection. All commands and status information between the SIMATIC controller and the robot are exchanged via this connection.
Downloads
https://bayfiles.com/ZemeA7s7o3/109772216_GettingStartedSRIYaskawa_DOC_V1_en_pdf
https://bayfiles.com/z3nbA2sdo6/109772216_GettingStartedSRIYaskawa_PROJ_MLxV125_TIAV15.1_zip
https://ulozto.net/tamhle/yUrtemvieSGr
https://vshare.is/Pcn9A0s1oa/109772216_GettingStartedSRIYaskawa_DOC_V1_en_pdf
https://vshare.is/rbo6A5s6ob/109772216_GettingStartedSRIYaskawa_PROJ_MLxV125_TIAV15.1_zip |
|
| Back to top |
|
 |
Herrerra
Junior
Joined: 29 Aug 2018
Posts: 1
|
| Posted: 29/06/2021 18:59 Post subject: MotoLogix Software |
|
|
| Does anyone can sharer MotoLogix Software? |
|
| Back to top |
|
|
|
|
You cannot post new topics in this forum
You cannot reply to topics in this forum
You cannot edit your posts in this forum
You cannot delete your posts in this forum
You cannot vote in polls in this forum
|
Powered by phpBB © 2001, 2005 phpBB Group
Fa-ti si tu propriul forum GRATUIT, pe www.myforum.ro |
 FAQ
 Search
 Memberlist
 Usergroups
 Register
 Profile
 Log in to check your private messages
 Log in


